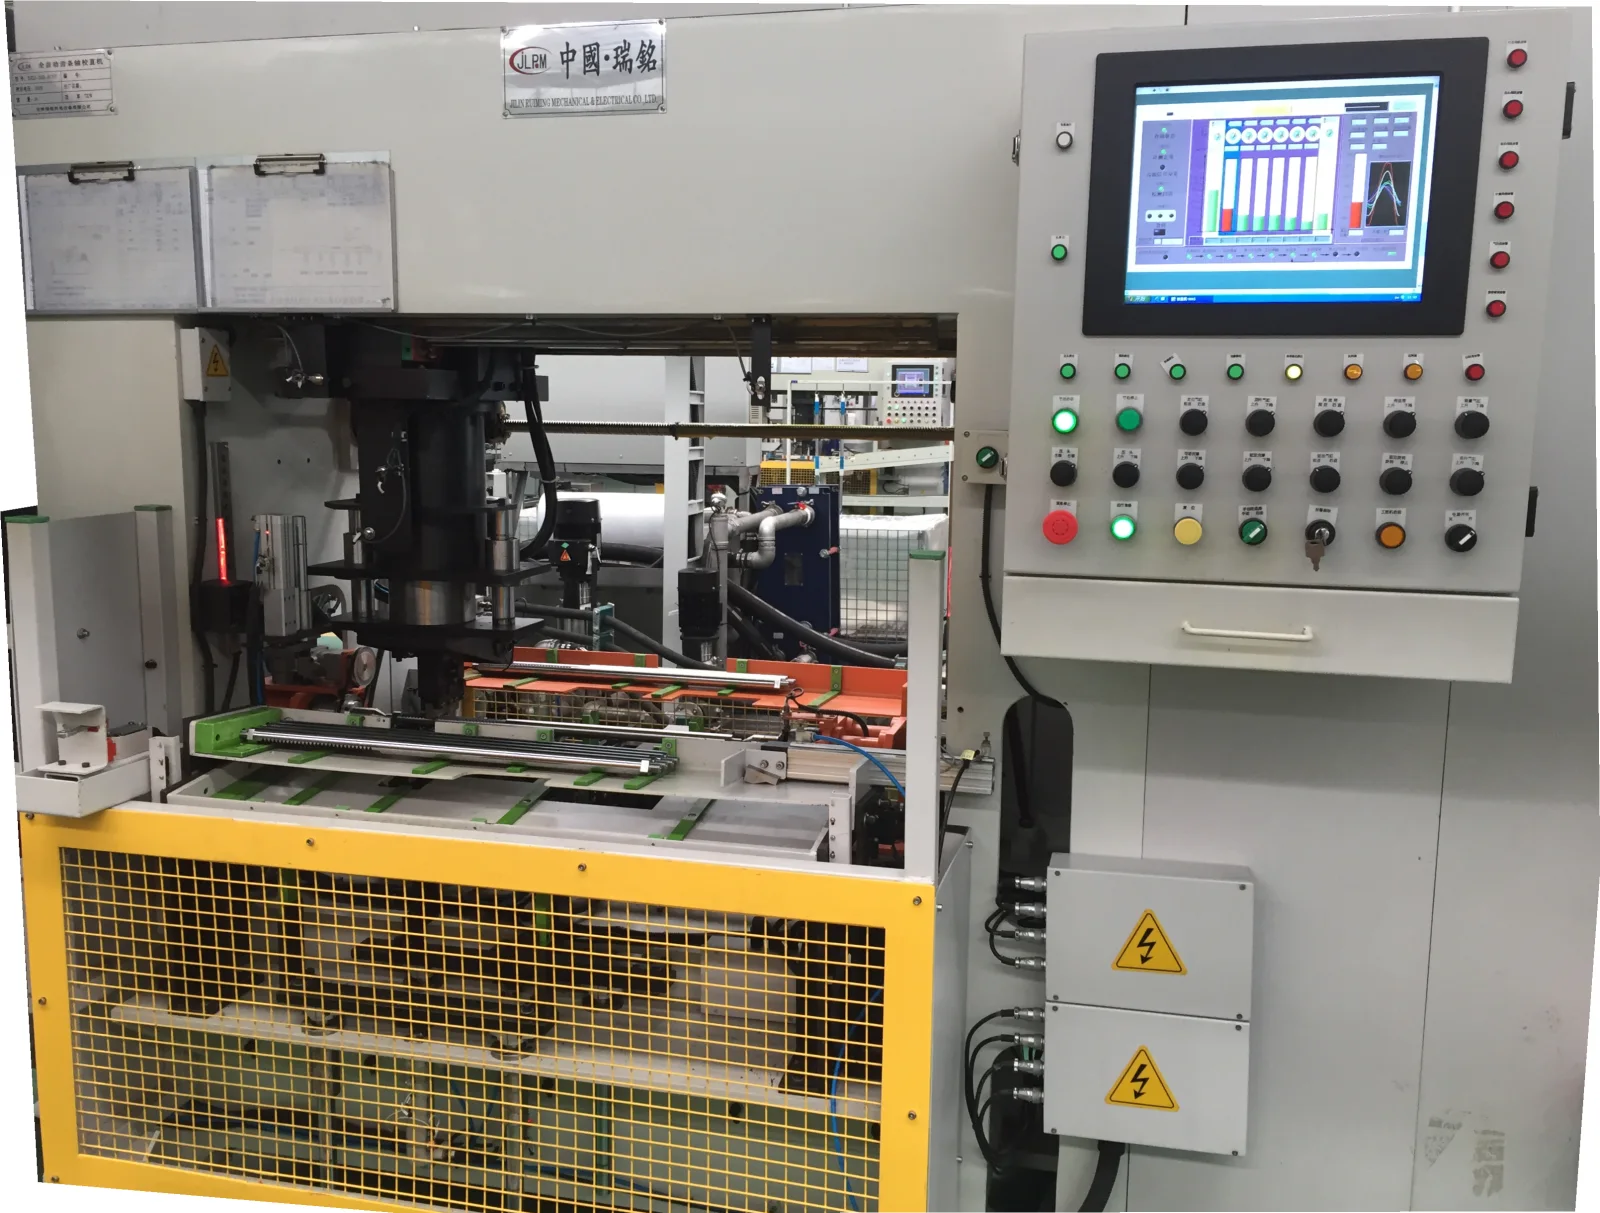
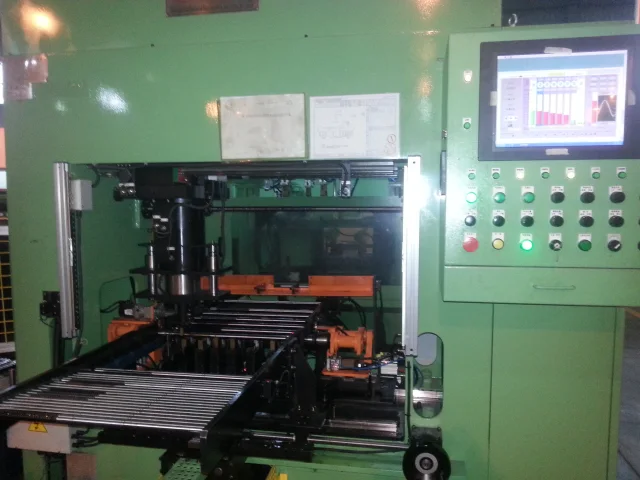
The workpiece is held between driven and follower centers. A variable-speed motor rotates the driven center, transmitting rotation through the workpiece to the follower. A measuring device linked to the movable supports measures total indicator reading (TIR), while an optical encoder at the follower center identifies its angular position. The computer determines the location and direction of maximum bending, stops rotation with that point facing upwards, and calculates the correction using the measured TIR and set parameters. A PLC controls clamping and release, support selection, worktable movement, and rapid and slow ram feed.